episode_0104
Incident Report
The receiving gripper must enter the handoff zone within 2.0 seconds of the workpiece.
- Workpiece enters
- 2.50 s
- Configured deadline
- 4.50 s
- Receiver enters late
- 5.00 s
Beyond the configured wait+0.50 s
Workcell incident intelligence
Metriplane turns recorded workcell state into an inspectable incident, preserved evidence and a repeatable test.

Same zone. 2.00 seconds to arrive.
The product
Timestamped workcell state, checked against the process you define.
Positions, identities and timestamps from a bounded workcell.
What must happen, where, and within how much time.
The incident, preserved evidence and a repeatable regression check.
01 / Inside the incident
Interactive walkthrough of the recorded demo.
Illustrative motion ·
archived event times.
handoff_zone
Receiver not in zone
Incident remains recorded
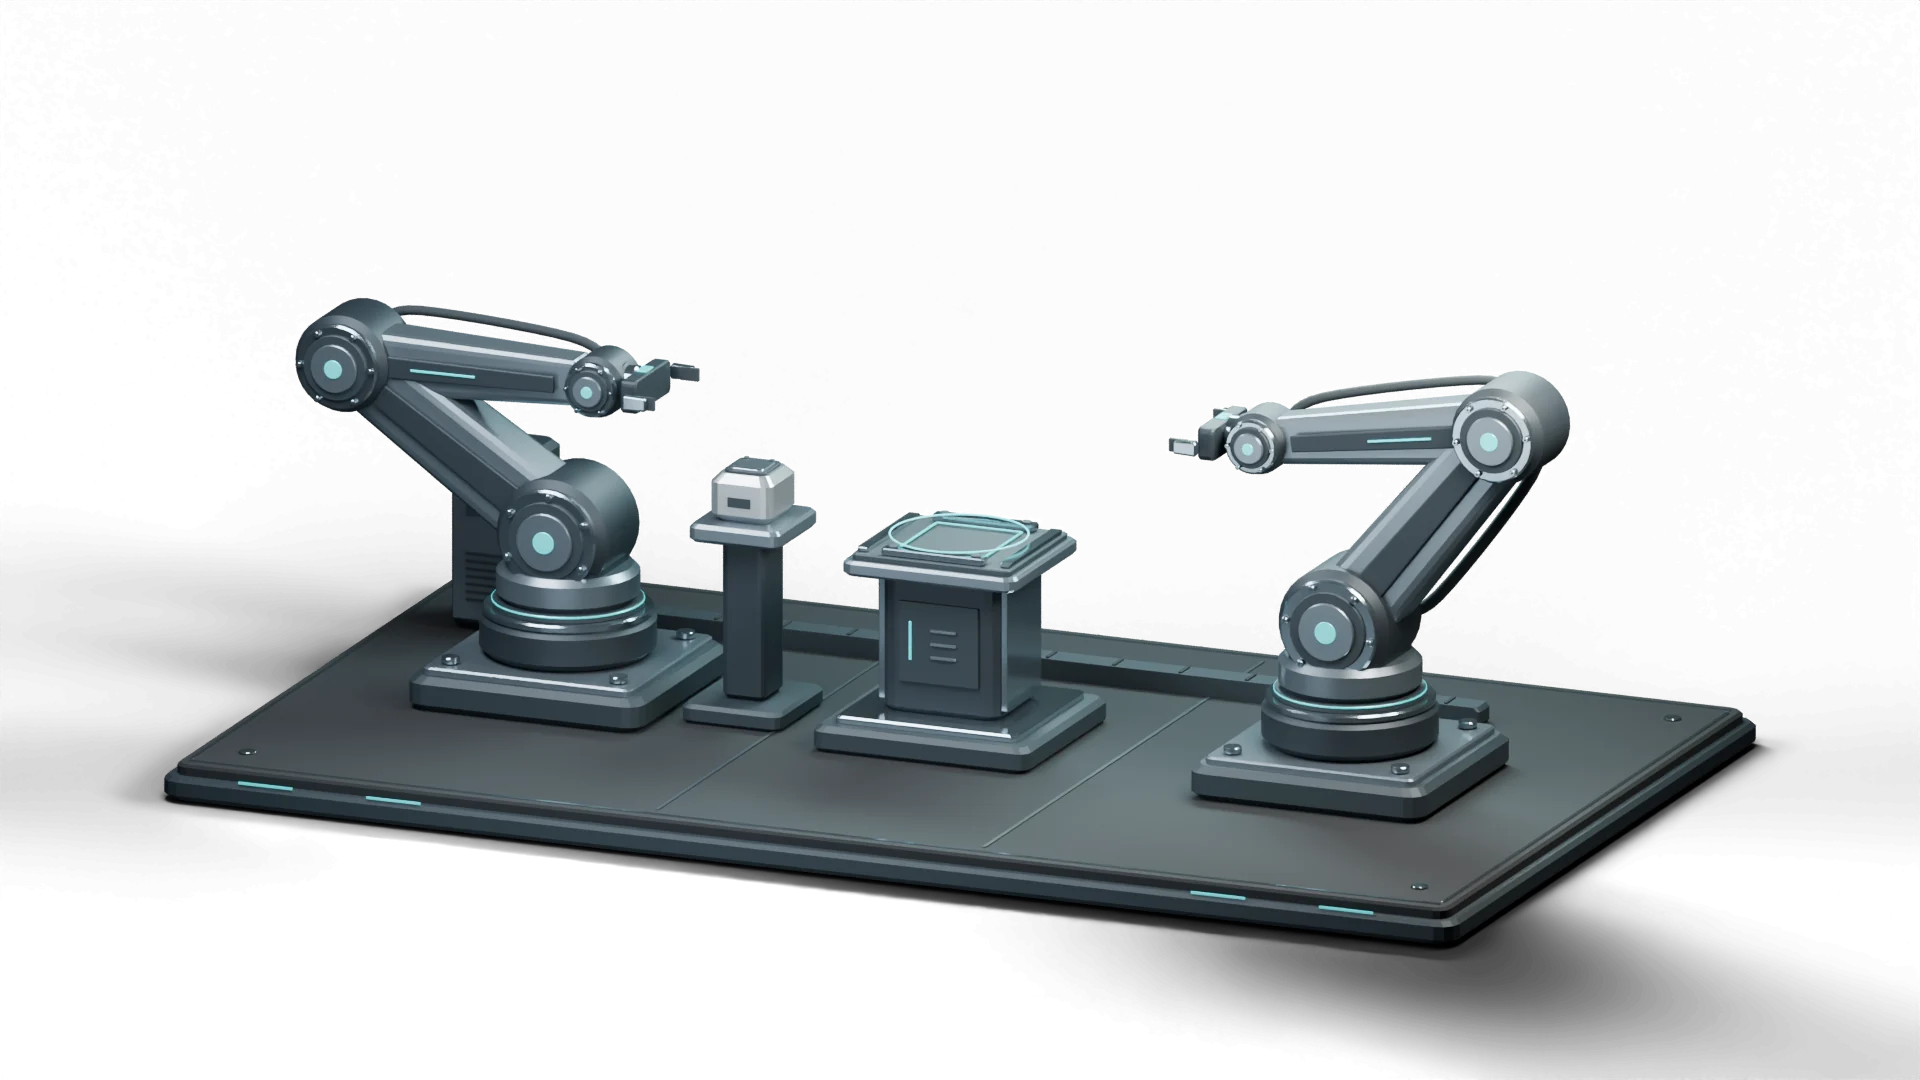
Before workpiece entry
Motion is an illustrative reconstruction. Event times and results come from the archived run. Scrub or select an event; camera changes preserve the recording time.
Case file overview
Preserved incident evidence
evidence_bundles/ Archived integrity-check result
The generated incident check
regression_tests/ Recorded verification result: PASS
The expected recorded incident
was detected again.
Archived production audit, 16 August 2026. The source recording is evaluated per episode; campaign aggregation is project-local. The film records an offline deterministic kinematic state source. This website uses the archived production reference for the counts, episode mapping and selected incident; it is not a fresh execution of the raw campaign.
The 3D workcell is an authored spatial illustration. Event times and occupancy labels follow the archived E0104 reference; the articulated motion explains the sequence and is not a recorded joint trajectory. Seeking evaluates the same illustration directly from the selected source time.
The 105 other episodes have no configured incident; this is not a safety or production-success classification. Watch the source film ↗ · Read the evidence boundaries
02 / From incident to evidence
Keep the incident understandable after the recording ends. Inspect the timeline and report, preserve the bundle, and detect the expected incident again.
Inspect this case’s evidenceReport summary from archived E0104. Explore the separate v0.2.0 research archive.
episode_0104
The receiving gripper must enter the handoff zone within 2.0 seconds of the workpiece.
03 / The recorded campaign
128 recorded handoffs.
23 missed deadlines.
Follow one into a repeatable check.
v0.3.0 demonstration
Each episode is evaluated independently. The campaign overview is a project-local aggregation.
Inspect the campaign
Watch the AGV film 00:52
v0.2.0 evidence workflow
Historical development demo · Public release
Historical development demo · Systems behavior
Historical development demo · Replay provenance
Historical development demo · Digital twin
Historical development demo · Fusion
Historical development demo · Camera to ROS 2
Historical development demo · Origin
Bring a recording
Metriplane begins with timestamped object state. The input path determines what you can evaluate.
A recorded case included with the Python package. No camera, GPU, ROS or Docker required.
Run locally 02 / INTEGRATION CONTEXTBounded ROS 2 and simulation demos translate supported state into Metriplane’s input contract.
Read the source boundaries04 / Try it locally
Start with the bundled missing-tool case. Six events, one incident, and a 35.0-second delay you can inspect.
Installation & support detailspython -m pip install "metriplane==0.4.1"metriplane demo --open Run in your terminal. The report opens in your browser.
The bundled example works offline after installation. The 128-episode campaign is a separate project demonstration.
05 / Open to inspection
Source, reproduction and research.
Each record keeps its exact
version.
Begin with your next question.